|
|
Rahul Vimalkanth
I am a final year undergraduate student in Electrical Engineering at
IIT Madras.
My research sits at the intersection of embodied AI, robot learning,
computer vision, and neurosymbolic systems, with a broader goal of
building intelligent systems that can perceive, reason, and act reliably
in the physical world. I am currently working in the
INSPIRE Lab
on robot learning for long-horizon manipulation, focusing on failure
awareness and recovery for vision-language-action models.
This past summer I was a Software Engineering Intern at
Adobe,
building a semantic layout engine for responsive interface generation.
At IIT Madras I was a
Young Research Fellow
working on efficient vision models for industrial anomaly detection with
KLA Corporation
,
and a researcher in the
Computational Imaging Lab
studying lensless gaze sensing and its privacy risks, both advised by
Prof. Kaushik Mitra
.
Previously, I worked with
Prof. Pradipta Biswas
at the
Robert Bosch Centre for Cyber-Physical Systems
,
IISc Bangalore
,
on pose estimation with dynamic 3D Gaussian splats.
Email
/
Scholar
/
LinkedIn
/
GitHub
|
|
I am broadly interested in embodied AI and robot learning,
with a focus on enabling agents to learn effective
representations from perception, reason over long-horizon
tasks, adapt across changing environments, and make reliable
decisions under partial observability and real-world
uncertainty.
Papers and preprints are ordered by recency. Please see my
Google Scholar
for a complete and up-to-date publication list.
|
|
Research and industry roles, ordered by recency.
|
|
Undergraduate Researcher
,
INSPIRE Lab
,
IIT Madras
Advisors:
Prof. Nirav Patel
,
Prof. Bijo Sebastian
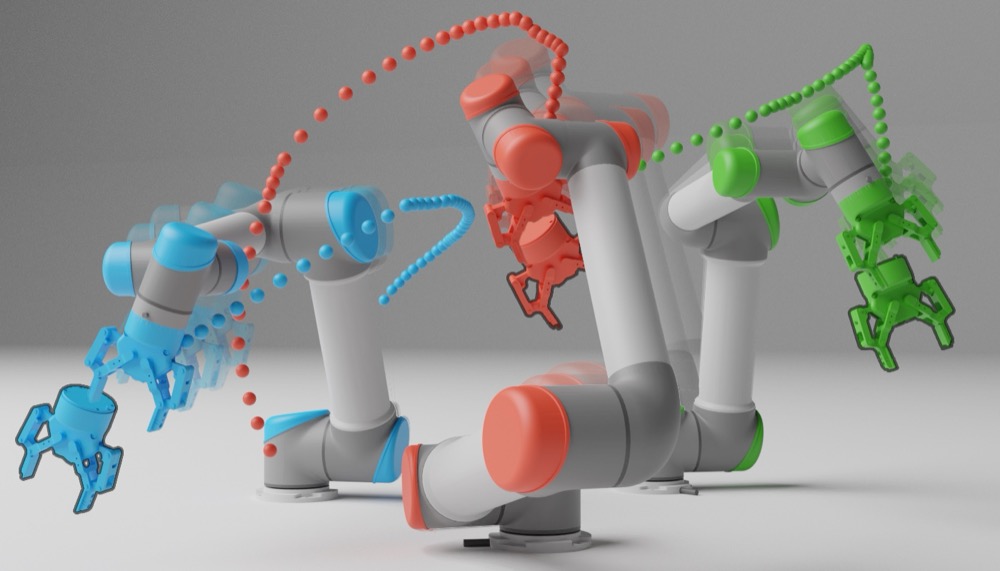
Researching failure awareness and recovery for
vision-language-action models in long-horizon robotic
manipulation, with a focus on identifying execution failures,
maintaining task-relevant state under partial observability,
and enabling policies to recover from compounding errors
across extended manipulation trajectories.
|
|
Frontier AI Fellow
,
Pathway
Researching memory architectures for long-context reasoning
and long-horizon decision making. The work develops a unified
state-update view of memory mechanisms spanning fast-weight
programming, retrieval-augmented generation, linear attention,
and test-time learning, and extends it to persistent memory
for agentic and embodied systems.
|
|
Software Engineering Intern
,
Adobe
Built a semantic layout engine that generates responsive
mobile interfaces in Adobe Captivate, combining graph-based
document reasoning with deterministic geometric planning and
bounded AI refinement to keep output predictable. Implemented
across C++, TypeScript, React, and the browser rendering stack.
|
|
Young Research Fellow
,
IIT Madras
· in collaboration with
KLA Corporation
Advisors:
Prof. Kaushik Mitra
,
Dr. Pradeep Ramachandran
Developed a knowledge-distillation framework for
prototype-based industrial anomaly localization, jointly
compressing the visual backbone and stored feature prototypes
while preserving the fine-grained spatial information required
for accurate defect localization. The approach enables
substantially more efficient inference with minimal degradation
in localization performance.
|
|
|
Undergraduate Researcher
,
Computational Imaging Lab
,
IIT Madras
Advisor:
Prof. Kaushik Mitra
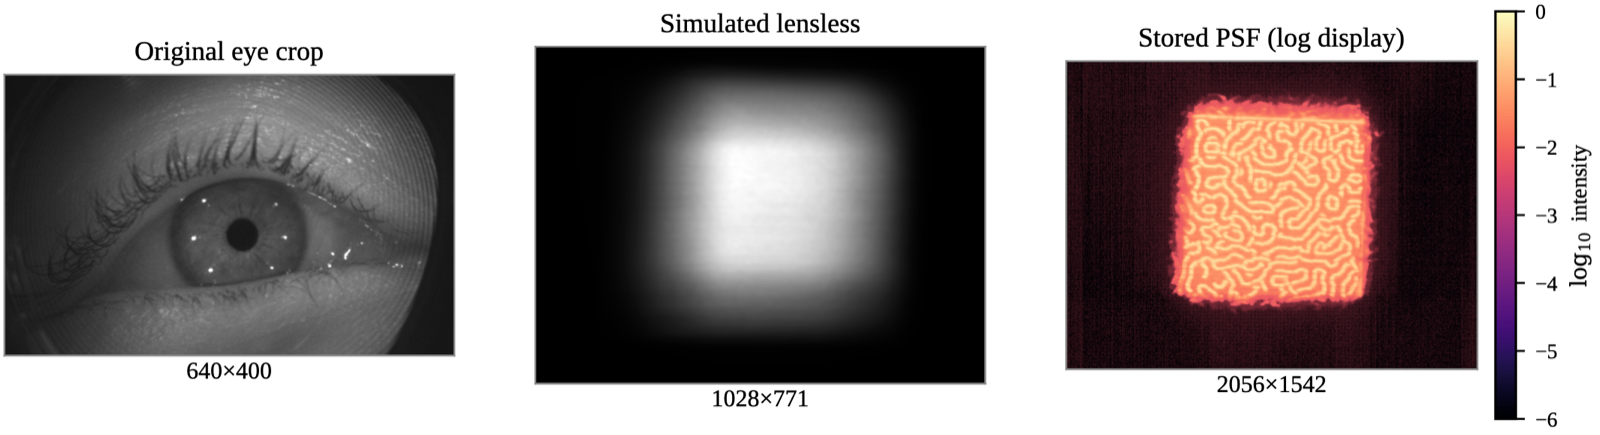
Developed a framework for auditing identity leakage in
lensless gaze sensing across optical, representational,
storage, and output surfaces, showing that visually
unintelligible measurements remain highly identifying.
Proposed a public-private feature representation that reduces
identity leakage while preserving gaze estimation accuracy.
|
|
AI Intern
,
Tattvam AI
Investigated abstract reasoning and program synthesis on
ARC-AGI benchmarks, which are designed to expose
generalization failures beyond language-model pattern
matching. Evaluated reasoning-oriented solution strategies
and parameter-efficient fine-tuning for few-shot task
adaptation.
|
|